Skip to content Skip to sidebar Skip to footer

Robotics

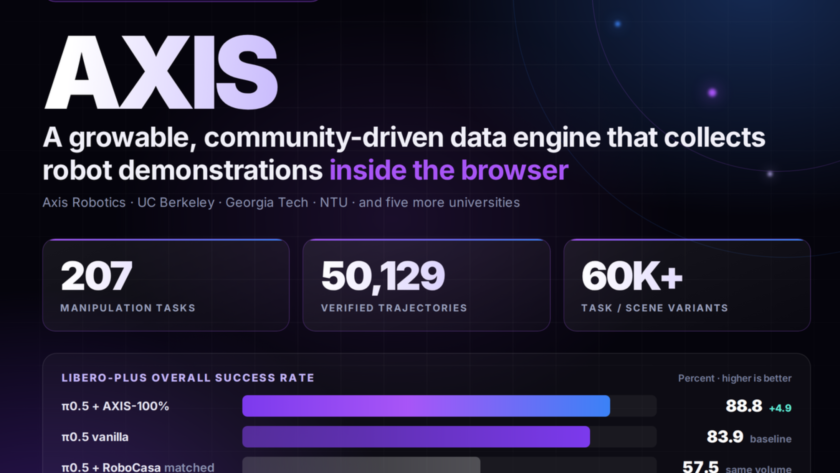
Axis Robotics Releases AXIS: A Browser-Based Data Engine With 207 Robot Manipulation Tasks and 50,129 Trajectories

Robot manipulation datasets have grown far slower than the models trained on them, mostly because collection stays closed and centralized. Expert operators gather demonstrations on lab hardware, process them offline, and ship a fixed benchmark that never grows again. A research team from Axis Robotics, UC Berkeley, Georgia Tech, NTU… is proposing a different shape…

Read More

Meet ‘Code-as-World’: An Agentic Loop That Rewrites Real Videos Into Executable MuJoCo Physics Programs

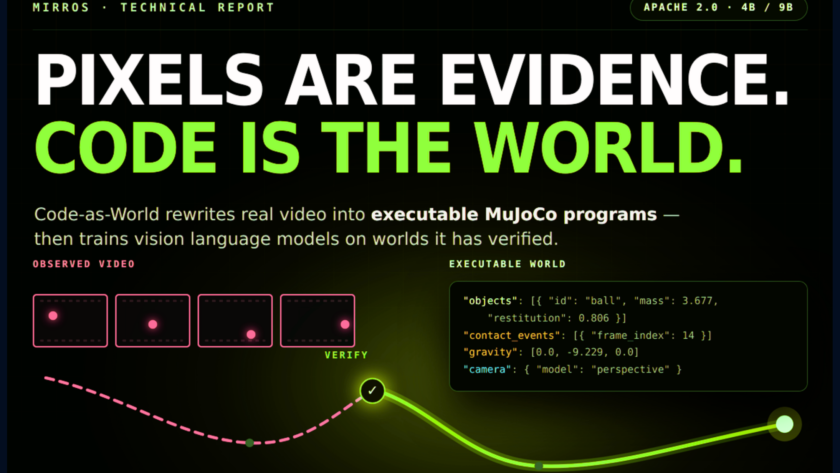
MirroS released Code-as-World: a paradigm that represents physical worlds through executable world representations. The argument is narrow and testable: pixels are evidence of a physical scene, not its ontology. A video model can predict plausible frames without ever representing mass, contact, or gravity. So instead of pixels, latents, or captions, Code-as-World represents a scene as…

Read More

Dyna Robotics Introduces Dyna-2: A World-Action Model Pre-Trained on 1 Million Hours of Human Video

Dyna Robotics has released Dyna-2, a world-action model for robot manipulation. It was pre-trained on more than one million hours of egocentric human video. That is roughly 170 years of continuous waking experience. Robot learning has been bottlenecked by action-labelled data, which teleoperation must deliberately produce. Dyna-2 tests whether ordinary human video can substitute. The…

Read More

Google DeepMind Ships Three Physical AI Models For Whole Body Control, Dexterity And Multi Robot Collaboration

Google DeepMind has released Gemini Robotics 2, the intelligence layer for its next generation of robots. The release moves the stack past table-top manipulation into whole body control, five finger dexterity and multi robot teamwork. It ships as three separate models with three different access tiers. Most robots today are pre-programmed or tele-operated for narrow,…

Read More

Mistral AI Releases Robostral Navigate: An 8B Model Enabling Robots to Navigate Complex Environments Using a Single RGB Camera

Mistral AI has released Robostral Navigate, its first model built for embodied navigation. The 8B model takes RGB images and a plain-language instruction, then moves a robot. Notably, it reaches 76.6% success on R2R-CE validation unseen using only a single RGB camera. What is Robostral Navigate? Robostral Navigate is an 8B model for robotic navigation…

Read More

Ant Group’s Robbyant Unveils LingBot-VA 2.0: A Causal Video-Action Model Built Natively for Physical AI

Robbyant, the embodied AI unit inside Ant Group, has released the LingBot-VA 2.0.The first embodied-native foundation model. It describes a video-action foundation model for generalist robot manipulation. The research team pretrains the whole stack for embodiment instead of fine-tuning a video generator. What is LingBot-VA 2.0? Most video-action models reuse two components built for digital…

Read More

NVIDIA AI Introduces ASPIRE: A Self-Improving Robotics Framework Reaching 31% Zero-Shot on LIBERO-Pro Long Tasks

Traditional robot programming is hard to scale. It requires orchestrating multimodal perception, physical contact dynamics, diverse configurations, and execution failures by hand. Code-as-policy systems let language models compose these into executable robot programs. That makes robot behavior inspectable, editable, and debuggable. But existing robotic coding agents run in naive execution environments. They receive only coarse,…

Read More